Spherical Robot
Undergraduate Research
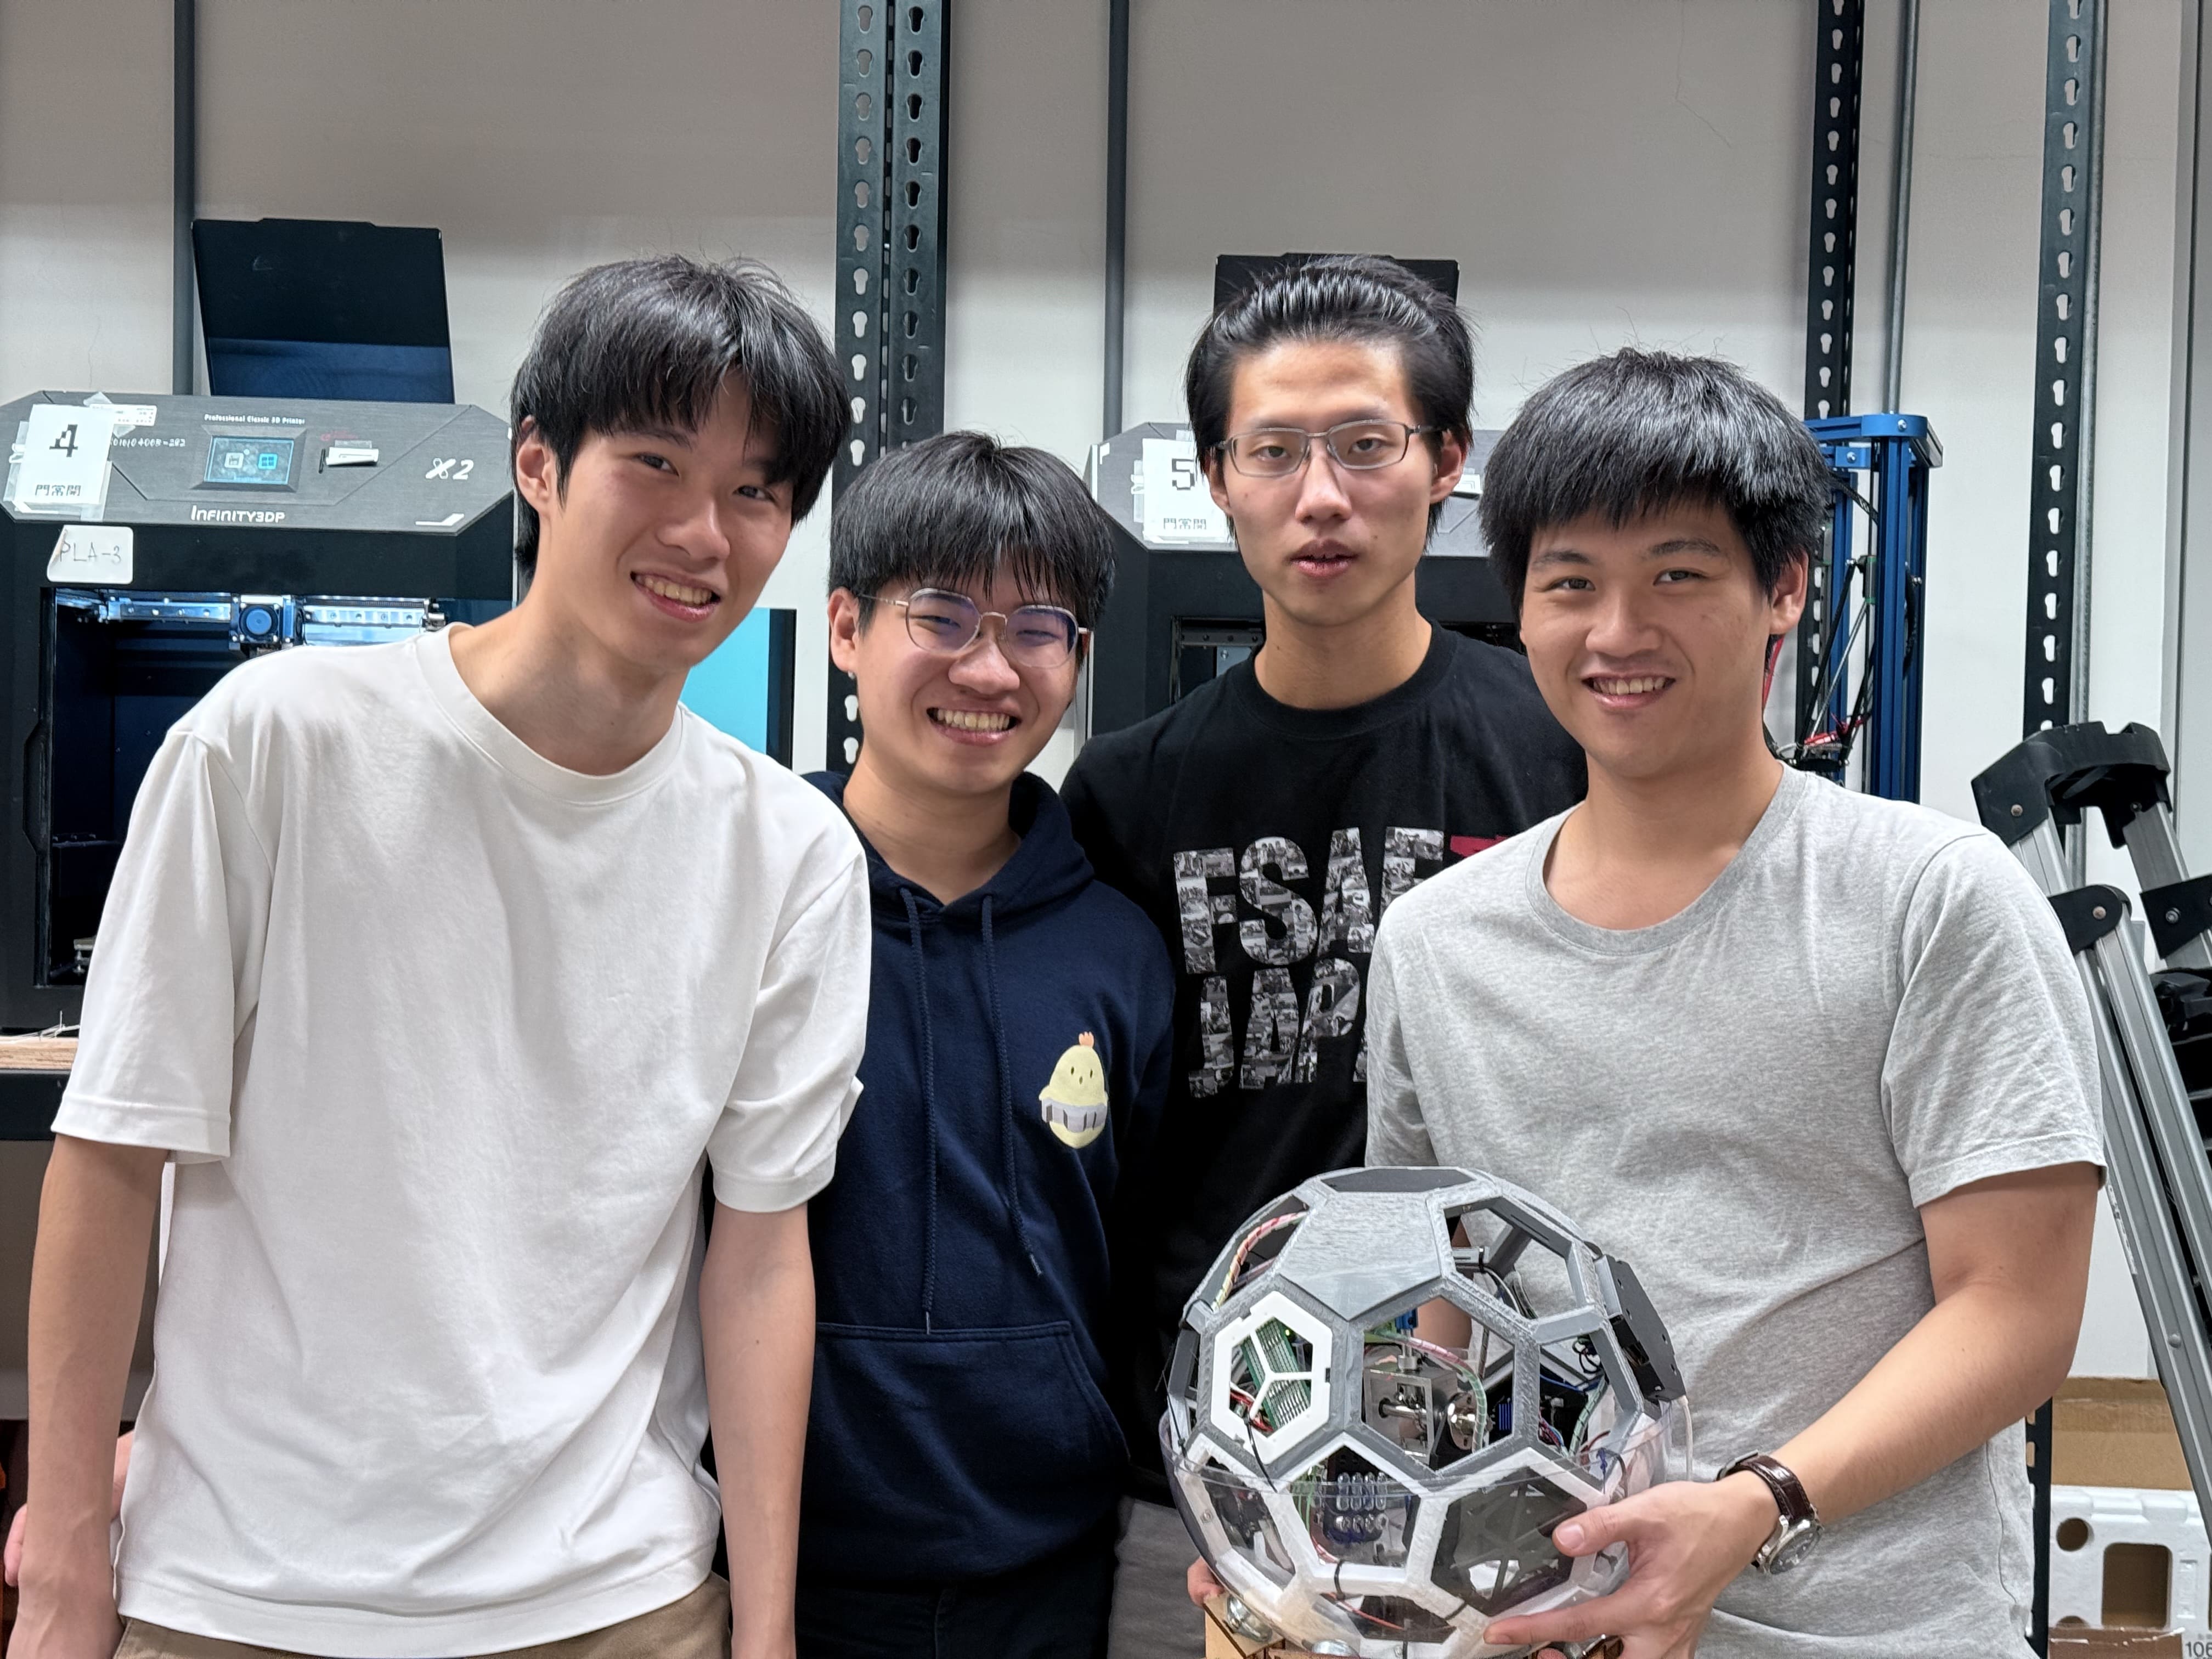
Dual-mode spherical robot with coaxial pendulum drive and impulsive momentum actuation, enabling omnidirectional rolling, side-rolling, and deformable terrain escape.
ME Ph.D. Student
Purdue University
I received my B.S. in Mechanical Engineering from National Taiwan University and am now pursuing a Ph.D. in Mechanical Engineering at Purdue University. My research interests lie in robotics, control, and machine learning, with a focus on robot learning and legged locomotion. Previously, I developed and controlled a pendulum-driven spherical robot and designed gain-scheduled LQR controllers with disturbance observers for rocket systems. I am currently working on humanoid robot control and evaluation.
Here are some of the projects I've worked on during my studies and personal time. Each project represents a different aspect of my learning journey and technical growth.
Undergraduate Research
Dual-mode spherical robot with coaxial pendulum drive and impulsive momentum actuation, enabling omnidirectional rolling, side-rolling, and deformable terrain escape.
Control Theory
Simulate and control a rocket for a self-landing task.
Mechanism Design
Designed a low-cost rapid energy release-mechanism to allow a robot cat to do backflip.
Fast Prototyping
Designed and built a 3D-printed atomic force microscope achieving 40-nm precision for graphene-layer imaging at a total cost of ~$3,000.
Analog Circuit Design
Developed an EOG-based eye-control system with custom circuitry, Arduino integration, and Unity interface, mitigating signal drift and noise.
Deep Reinforcement Learning
SAC-based HalfCheetah locomotion with domain randomization and morphology-aware inputs, enabling robust zero-shot generalization across leg lengths and friction.
Deep Reinforcement Learning
Trained a Double Dueling DQN with Noisy Networks, n-step returns, and curriculum learning to complete World 1 of Super Mario Bros within 5,000 episodes.
Kinematic & Trajectory Planing
Designed a stair-climbing robot with cubic polynomial trajectory planning and Denavit–Hartenberg parameters for smooth, accurate motion.
Digital Circuit Design
Developed an automated medicine sorting machine for the elderly, integrating a light-based system with photoresistors, a Schmitt trigger, and logic gates to reduce GPIO pin usage by 25%.
Machine Learning
Developed a phone-use detection chair that identifies users on their phones and automatically pushes them off to discourage distraction.
Product Design & IOT
Developed a smart wardrobe that locates and recommends clothes; designed exterior, selected materials, and integrated pressure sensors for clothing tracking.